AI Engineer and Researcher

Vo Thanh
Nguyen

My research and engineering focus on building intelligent, autonomous systems and cognitive agents that perceive the physical world, reason over complex environments, and make robust real-time decisions. I work across world models, computer vision, multi-agent operating systems, and autonomous driving stacks.

I have been fortunate to pursue these works under the mentorship of Dr. Bui Ha Duc (HCMUTE, Ph.D. from NUS).

Research

Recent work

01
Prediction
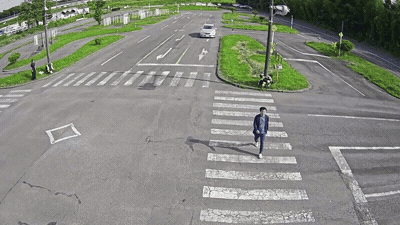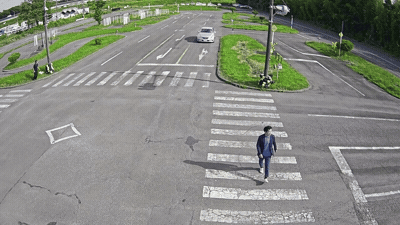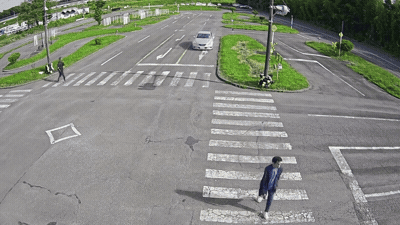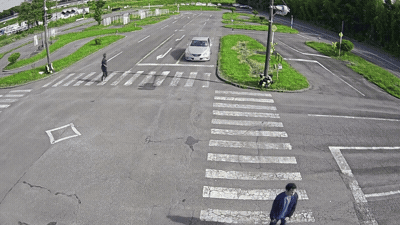
Overhead-view generated traffic forecast after condition frames Vehicle-view generated traffic forecast after condition frames
Ground truth
Overhead-view ground-truth traffic continuation after condition frames Vehicle-view ground-truth traffic continuation after condition frames

World Models · V-JEPA · Generative AI · 2026

Generative Traffic Forecasting with World Models

Introduced a decoupled forecasting framework that uses frozen V-JEPA representations to guide a frozen video diffusion model through a lightweight learned alignment module, separating traffic-world understanding from pixel-level generation.

  • 3rd place, AI City Challenge 2026 (Track 5)
  • Paper accepted at ECCV 2026 Workshop
02
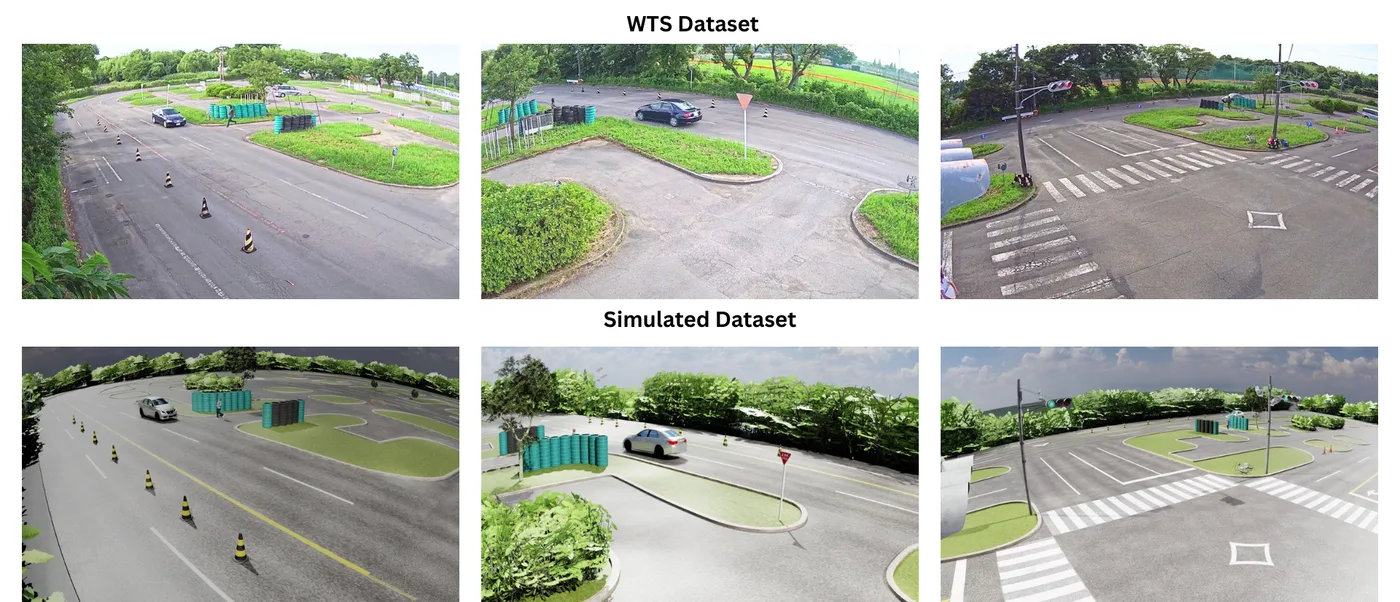
Side-by-side real WTS and simulated traffic scenes demonstrating sim-to-real traffic understanding

Vision-Language · V-JEPA · 2026

Traffic Scene Understanding with World Models

Introduced a structured traffic-scene understanding framework that uses frozen V-JEPA representations to predict explicit semantic facts, then applies training-free relational and temporal refinement before grounding caption generation.

  • 1st place, AI City Challenge 2026 (Track 2)
  • 87.09% question-answering accuracy
  • Paper accepted at ECCV 2026 Workshop (Oral)
03
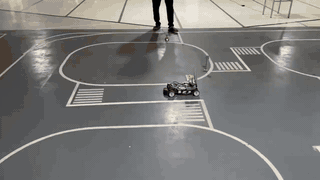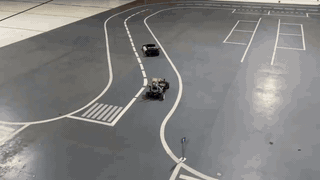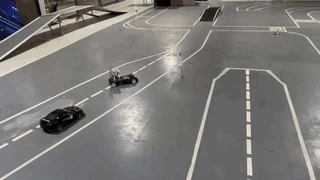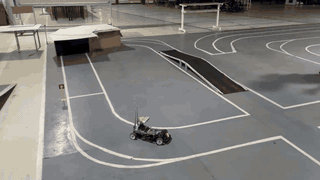
BFMC 2026 autonomous qualification run

Autonomous Driving · Edge AI · 2026

Bosch Future Mobility Challenge 2026

Led the software stack development for our autonomous vehicle team (“Drive Beyond”), building an end-to-end model that converts camera images and navigation commands into drivable trajectories and object detections, with lane following and decision making for robust on-track navigation, deployed on NVIDIA Jetson Orin Nano.

  • Semi-finalist & Recipient of 150M VND Bosch Sponsorship
  • 1st nationally in the 2026 qualification round
04
1 / 5

Autonomous Driving · Robotics · 2025

Bosch Future Mobility Challenge 2025

Led software stack development for our autonomous vehicle, building real-time perception, navigation, and control capabilities that carried the team to the international finals.

  • Global top 9 at the international finals
  • Best Team from Vietnam & Asia (2025)
  • Finals hosted by Bosch Romania

Engineering

Projects

05

Multi-Agent Systems · LangGraph · RAG · 2025–2026

KnowledgeForge (Agent Operating System — AOS)

Architected an enterprise-grade Agent Operating System in Python and LangGraph that decomposes complex tasks into concurrent DAG execution via Kahn’s Topological Sort. Integrates an MCTS decision engine, runtime AST-based safety validation & skill hot-patching, and a reactive SSE streaming gateway.

  • Sub-10ms Semantic Router & MCTS Planning Engine
  • Continuous Empirical Learning (CEL) & AST Hot-Patching
  • Multi-platform webhook delivery (Zalo, Discord, Telegram, Slack)
06

Computer Vision · Real-Time Systems · 2024

Real-Time Driver Distraction Detection System

Engineered a real-time driver state monitoring system running across multiple worker processes, fusing 6 biometric signals through a temporal state machine and rendering a live operator HUD.

  • Signal Fusion: EAR, MAR, Head Pose, PERCLOS, Blink Rate, YOLO
  • Multi-backend inference with hot-swappable runtimes
  • PySide6 live HUD with face-mesh overlays
07

AI Automation · n8n · Qdrant · Contract

Enterprise AI Workflow Automation

Designed and deployed 10+ end-to-end n8n workflows for a media company: AI-assisted article writing, social media copy generation, scheduled auto-posting, document drafting, and news aggregation via vector search (Qdrant).

  • 99.8% workflow uptime with retry-backoff error handling
  • Cut manual content-production time by 70%
  • Reusable LLM API + custom Python nodes

Experience

Work & education

AI Engineer and Researcher

University Research Lab, HCMUTE

Researching predictive world models, traffic scene understanding, and autonomous vehicle control. Co-authored 3 publications (ECCV 2026 Workshop Oral/Poster, GTSD 2026) and led autonomous driving software stacks in BFMC.

AI Researcher

3DVision Lab, HCMUTE

Designed deep-learning industrial vision pipelines for PCB defect detection (for BACKER, 98.2% accuracy) and engineered multi-process zero-copy IPC via Linux SharedMemory across TensorRT, OpenVINO, and ONNX (3.2x CPU throughput speedup).

B.Eng. Robotics & Artificial Intelligence

HCMUTE · Expected 2026

Winner (Top 1) Track 2 & Top 3 Track 5 in AI City Challenge 2026 (ECCV Workshop); Top 5 Finalist Datathon 2026; Third Prize ICPC National Contest (2024); Second Prize OLP (2023, 2022); Talent Scholarship Recipient.

Le Quy Don High School for the Gifted

Specialized in Informatics

Solid algorithmic foundation in competitive programming and computer science.